I am a Ph.D. student in Computer Science at the
University of Virginia,
advised by Prof. Yen-Ling Kuo
in the Link Lab. My research focuses on robust robot learning,
tactile and force-regulated manipulation, and
human–AI/robot collaboration. I am particularly interested in enhancing
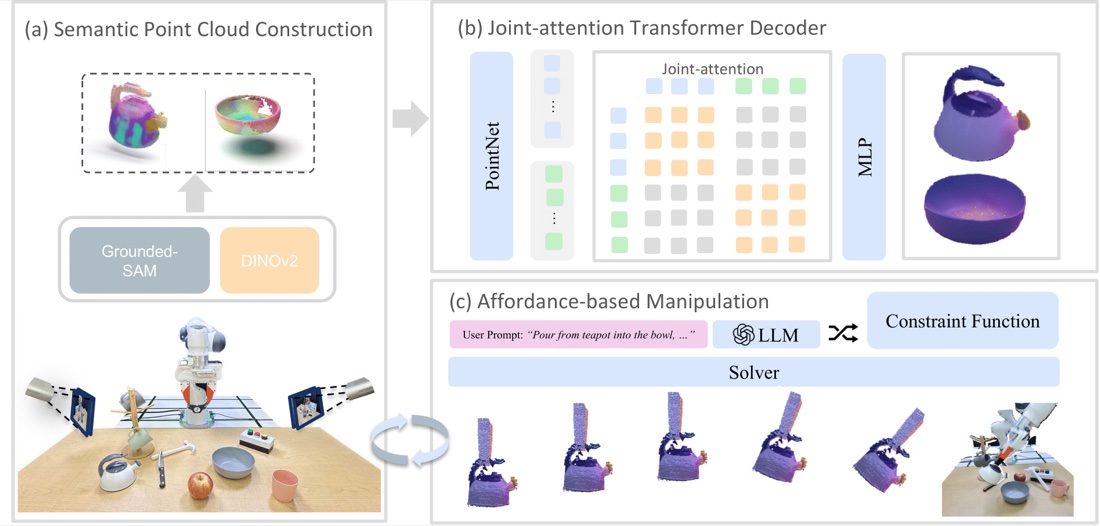
AI models' perception and understanding of the physical world, with the goal of building
generalizable and robust robotic systems that can perform real-world tasks and collaborate
effectively with humans.
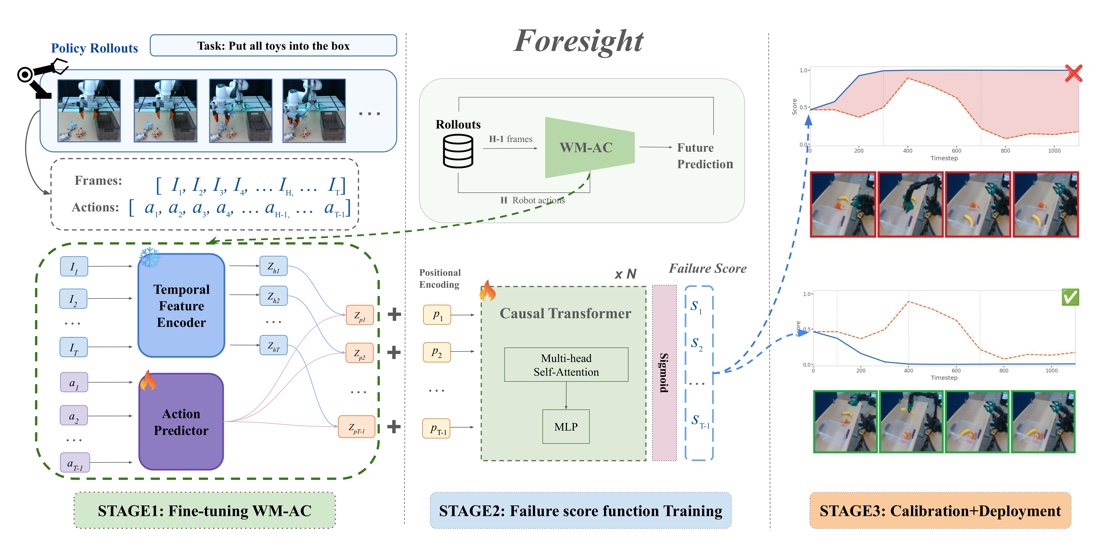
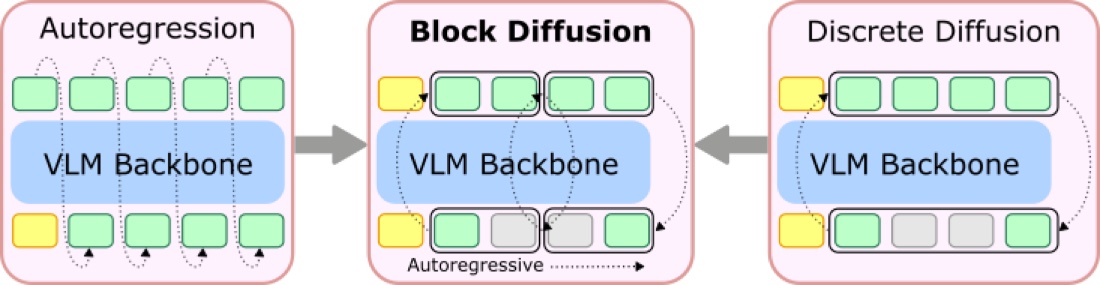
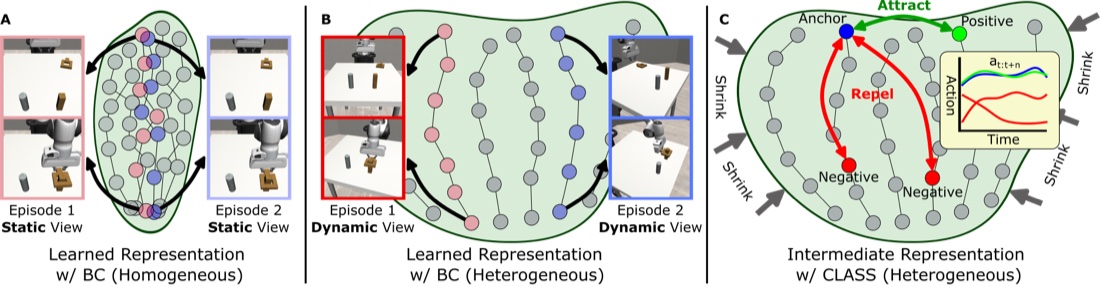
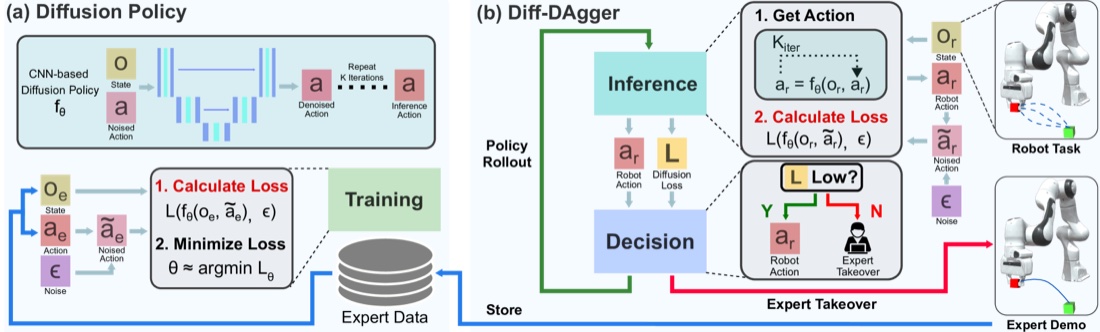
Robust robot learning: adapting pre-trained robot policies and vision-language-action models so they stay reliable under distribution shift
Tactile and force-regulated manipulation: low-cost tactile and force-controlled hardware, and policies that regulate contact force for delicate objects
Human–AI/robot collaboration: physically-grounded collaboration with diverse human partners